Introduction/Summary:
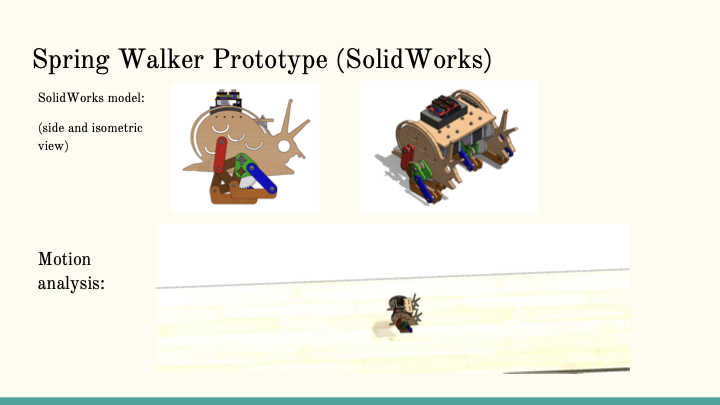
The purpose of this project is to design and manufacture a spring walker using "four bar linkage" to drive the movement.
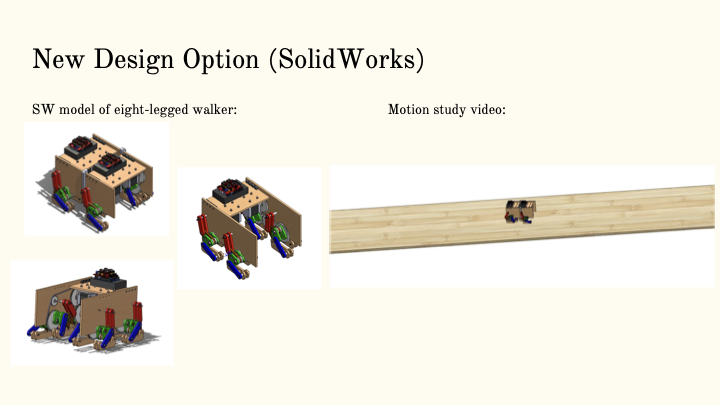
A design iteration is conducted to increase the number of "legs" of the robot. Kinematic analysis of the linkage was conducted using Geogebra and the motion analysis in simulation was conducted using Solidworks motion analysis.
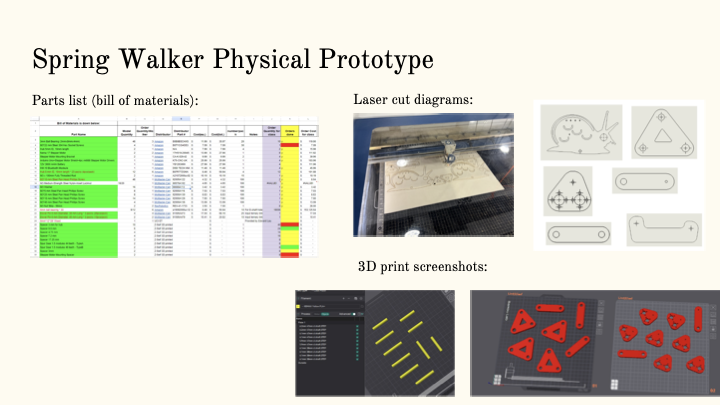
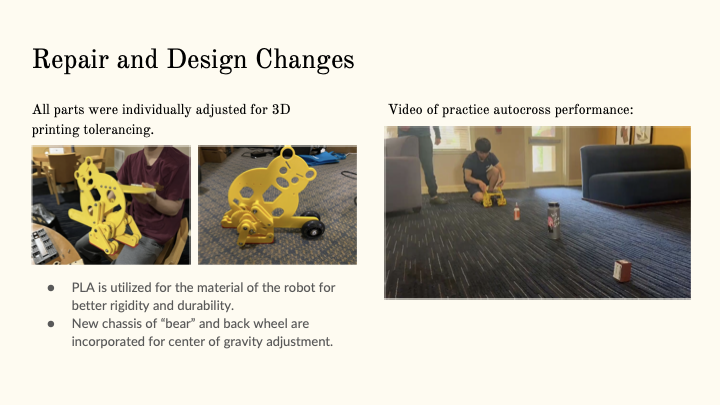
Materials utilized for the robot are wood and pla plastic. Manufacturing methods included laser cutting and 3d printing.
Please enjoy :)
This site was created with the Nicepage